Start with the decision.
Clarify what the team needs to learn or choose before adding more work.
Sometimes that means building a robot. Sometimes it means taking a seat apart, running a simulation, or machining a part for my telescope.
I’m a fourth-year MEng Design Engineering student at Imperial College London, focused on robotic systems and physical products. My recent experience spans robot workflow development and testing at Dobot Robotics, ForceVLA contact-risk research at SUAT and companion-robot R&D at TCL.
Clarify what the team needs to learn or choose before adding more work.
Use research, code, simulation or a physical prototype—whichever answers the question most directly.
Turn the result into a recommendation, a handoff or the next experiment.
Each area leads to the work behind it.
I connect kinematics, control, sensing and hardware into robot behaviour that can be tested on the physical system.
7 projects ↗02I bring user needs, technical constraints and product goals into the same decision.
8 projects ↗03I use FEA, CFD and data models to narrow the design space, then check key assumptions with another method where the project allows.
6 projects ↗04I design form, mechanisms and feedback together so physical products make sense in use.
5 projects ↗05I build software, data tools and visualisations that expose system state and support debugging or decisions.
6 projects ↗Coursework and projects span robotics, product systems, simulation, physical computing and interactive software.
Franka · Waypoint-Based Brick Stacking ↗Fit EMG Product Strategy ↗Sustainable Aircraft Seat ↗Hands-on work with humanoid and wheeled robots, covering robot operation, policy-related work and hardware assembly.
Dobot Robotics ↗Explored trajectory ranking and simulation, then studied temporal contact-risk prediction and ForceVLA integration through offline experiments.
SUAT · Force-Aware VLA Research ↗Worked on Ai Me motion testing, actuation and internal layout, coordinating with the textile team on the prototype shown at IFA 2025.
Ai Me Companion Robot ↗More than a decade of deep-sky imaging, calibration and making small parts to improve optical setups.
I’ve photographed the night sky for more than ten years. I enjoy adjusting the equipment and working through the images to bring out faint detail.
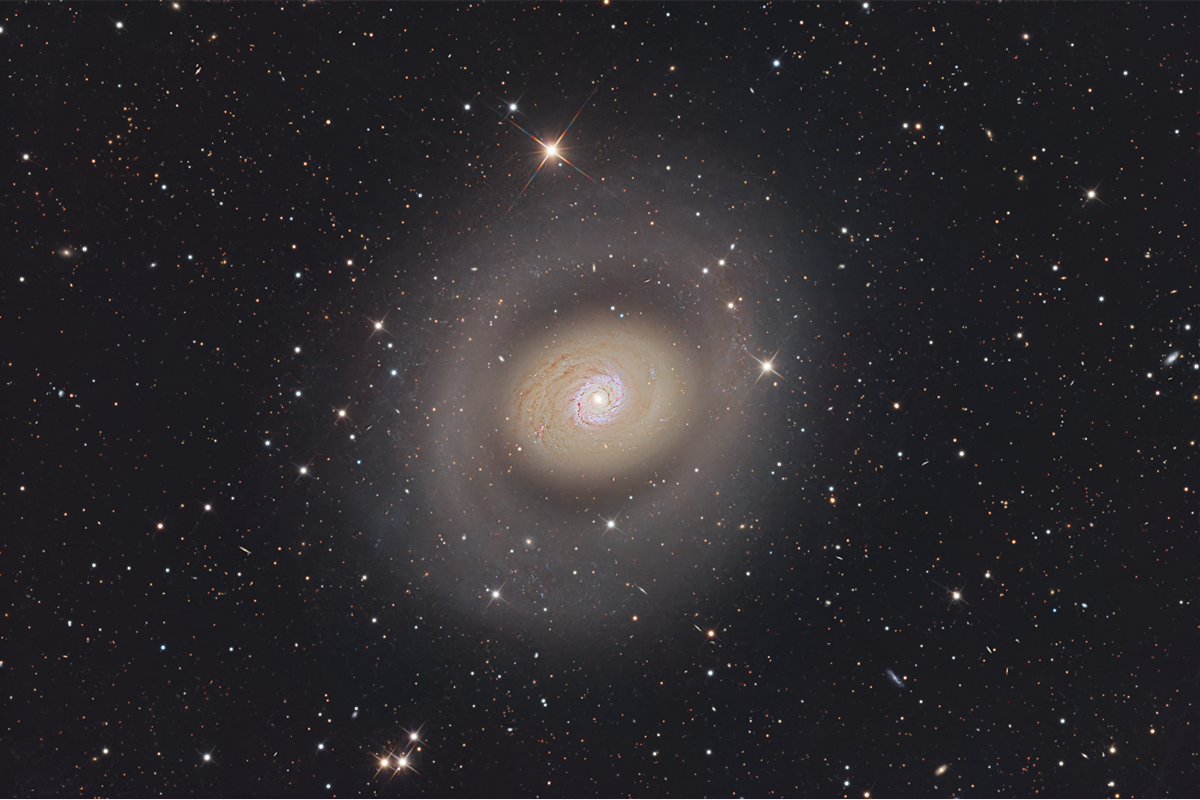
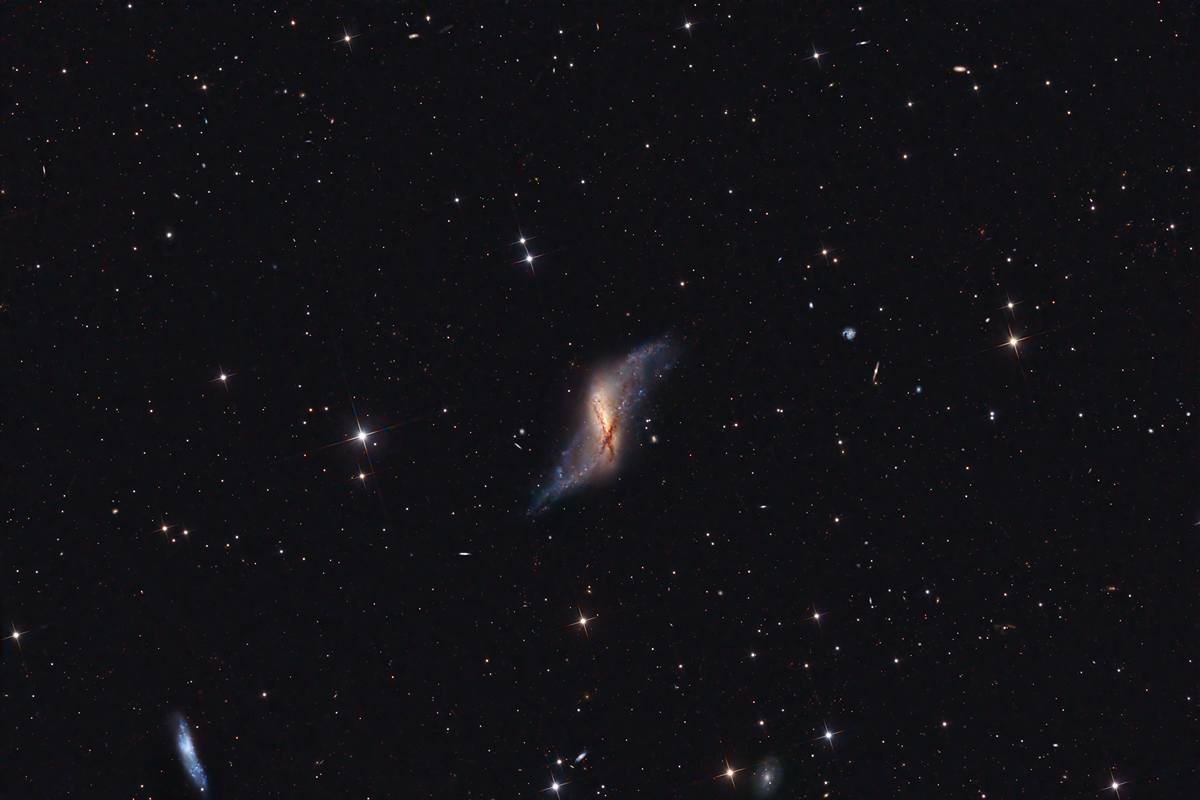
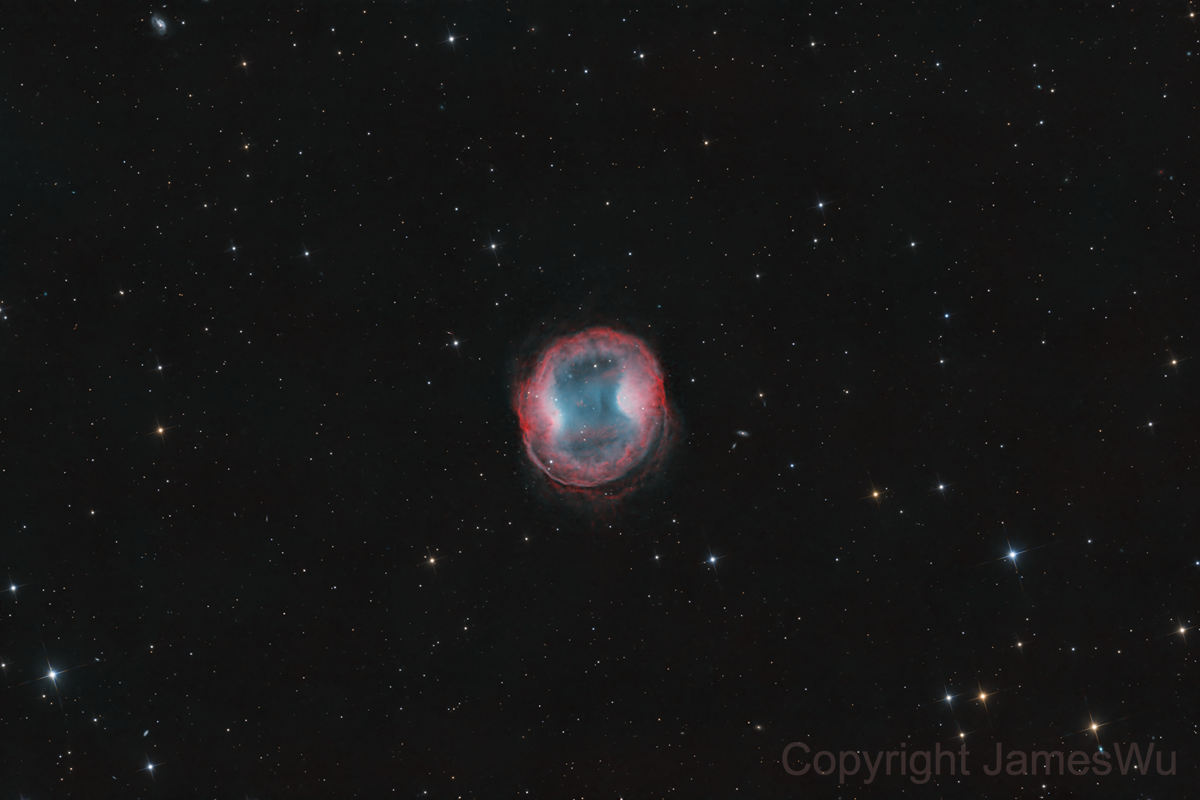
When standard hardware is not quite right, I design and machine small parts to improve alignment and repeatability.
If you have a role in mind, a project to work on, or a question about something here, I’d be glad to hear from you. I’m based between London and Shenzhen and open to remote collaboration.
james1525255232@outlook.com ↗