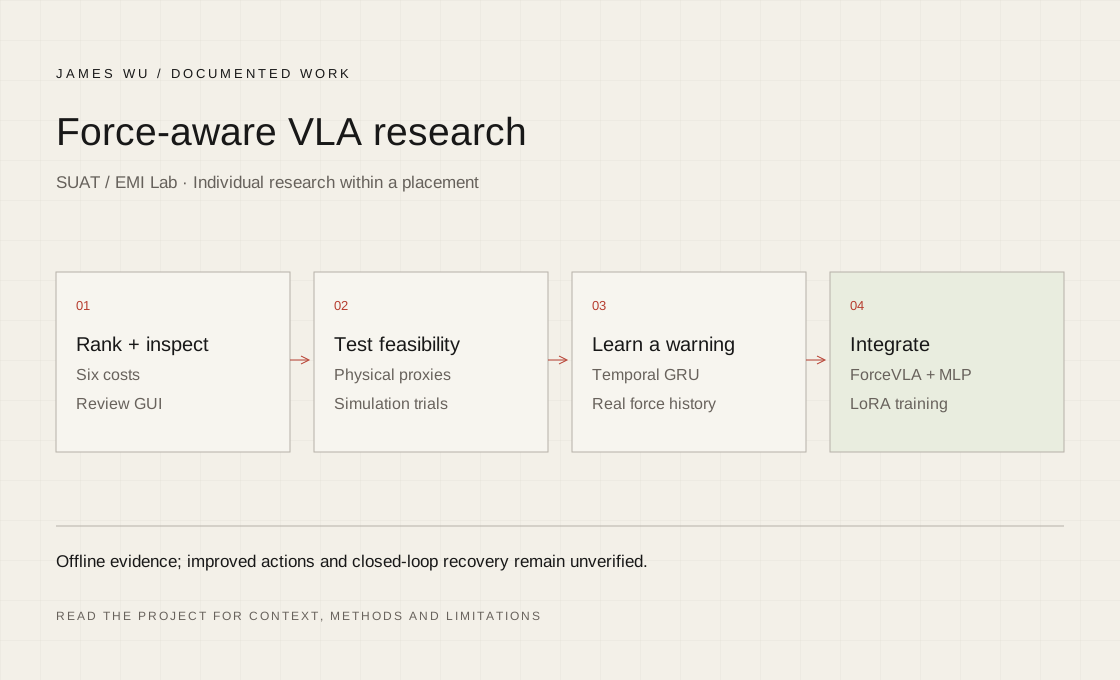
A standalone temporal model outperformed a current-force heuristic offline. The integrated ForceVLA risk head also learned the proxy risk signal; reliable action improvement and closed-loop performance remain unverified.
Independent projectIndependent research: trajectory ranking, simulation and risk-head training
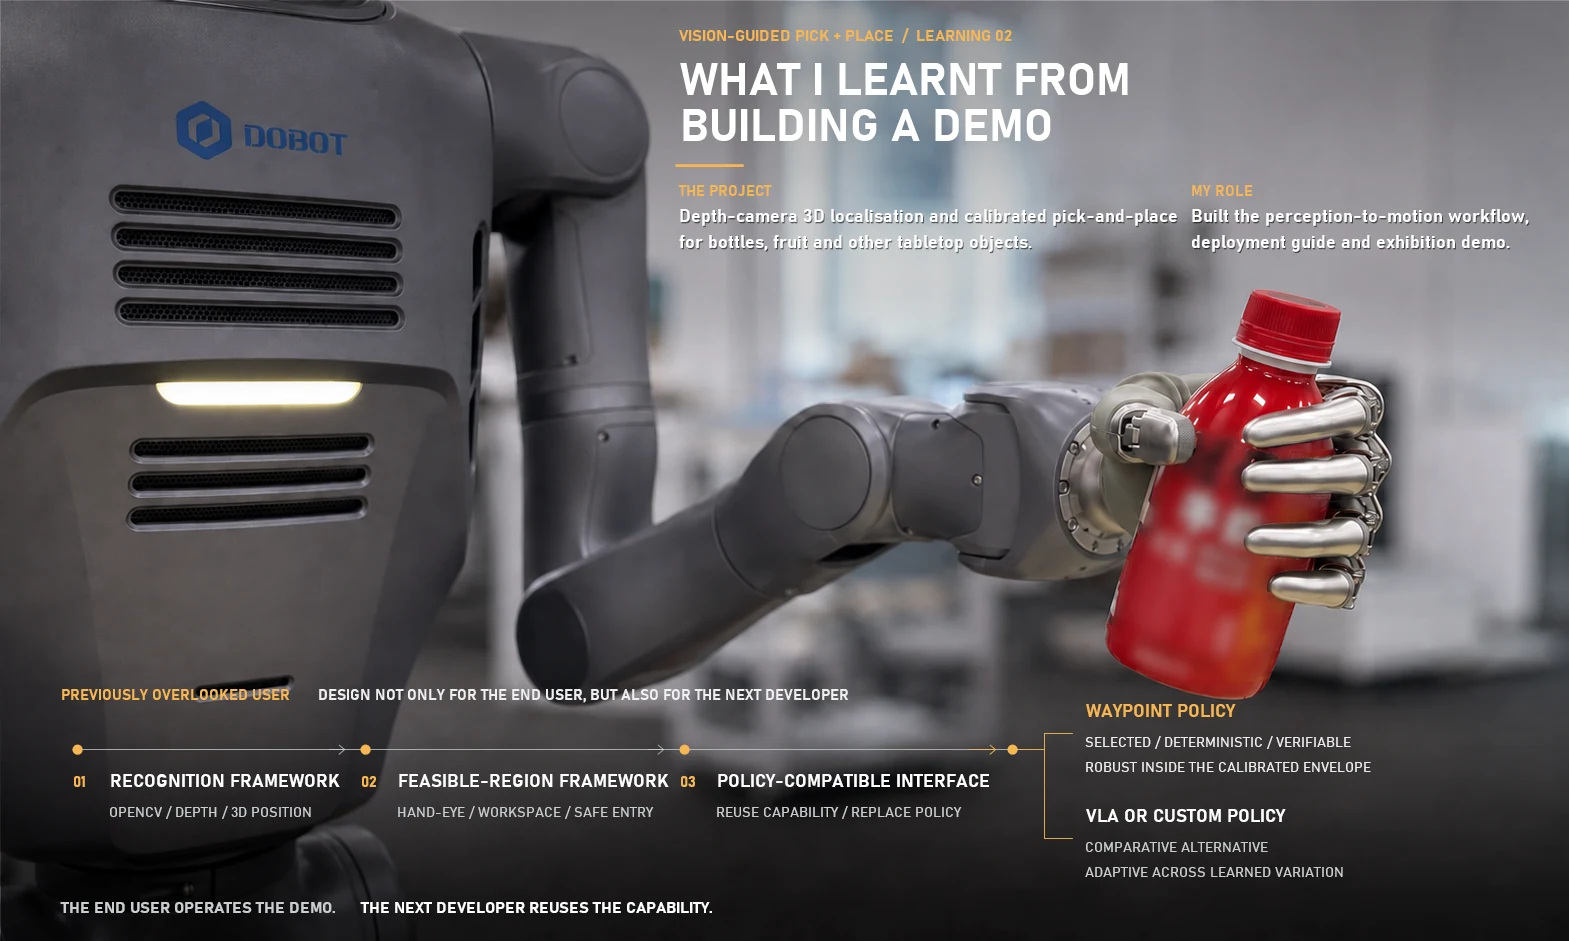
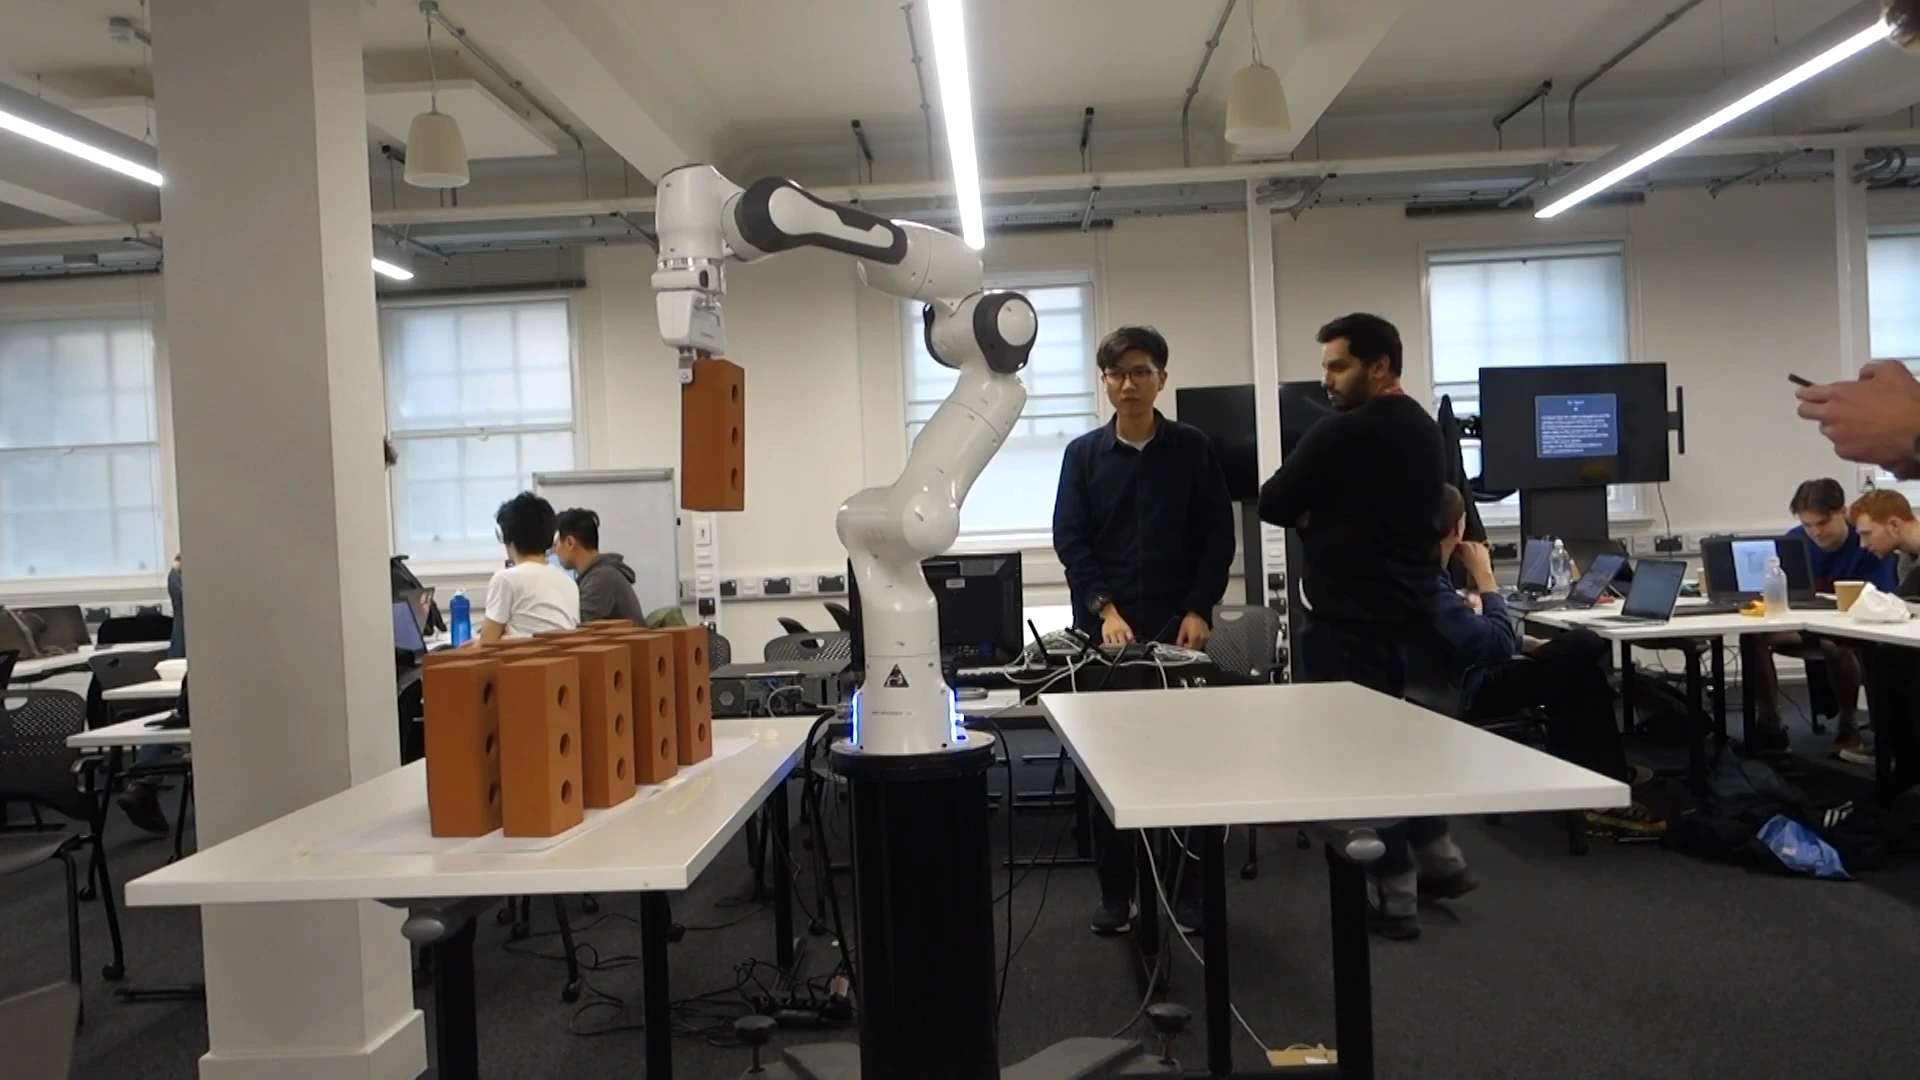
Hands-on experience connecting physical robots, perception, control and services through task demonstrations, teleoperation, navigation experiments and hardware work.
My partTechnical Support Engineer Intern · robot applications and testing
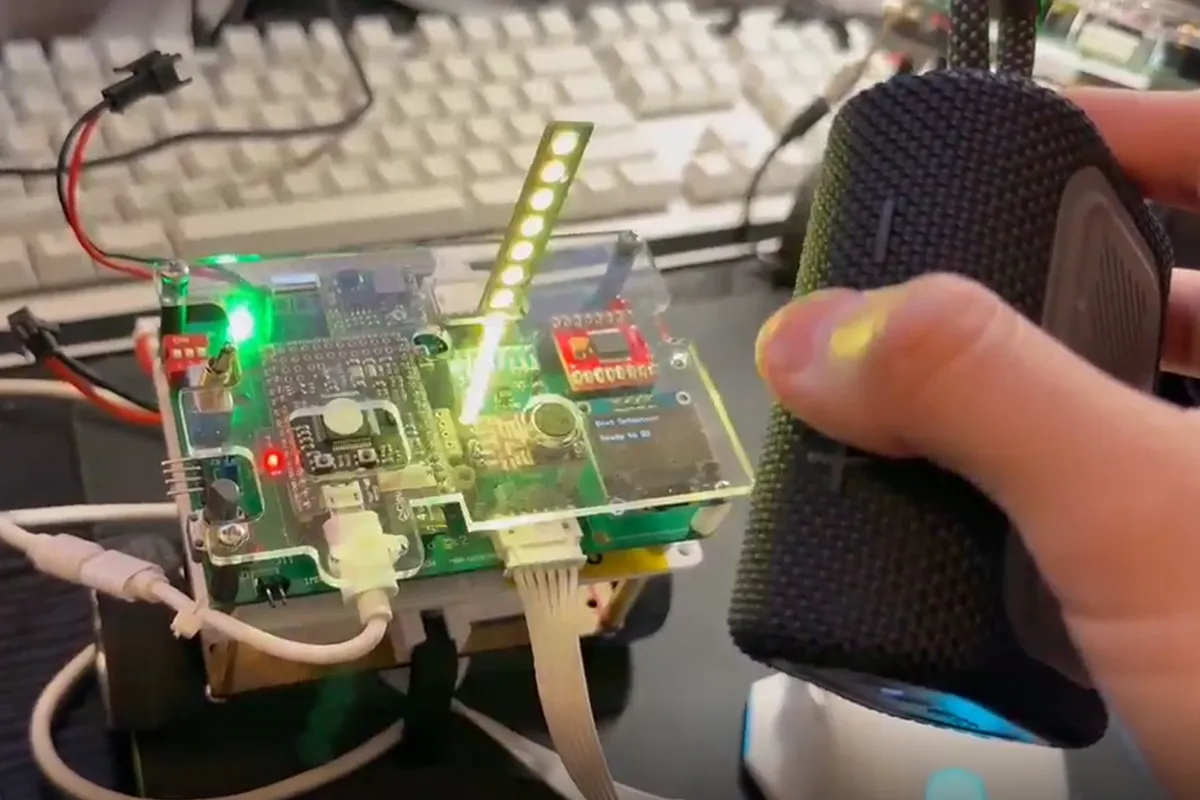
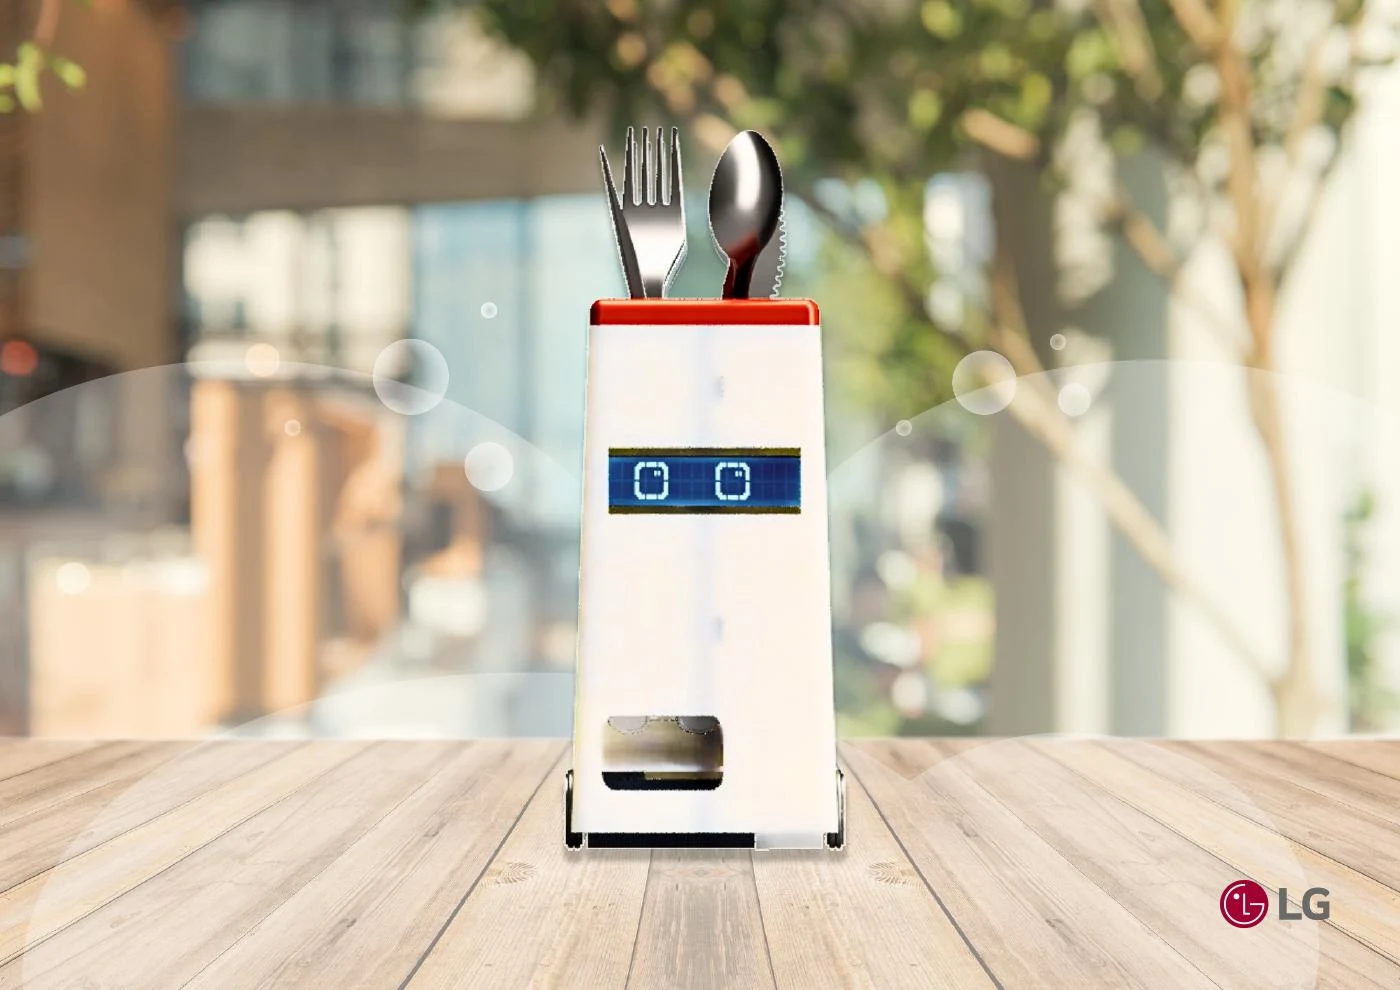
Built and tested a physical prototype, identifying fit, wiring, power and control issues. The production-oriented CAD proposes injection-moulded parts and modular assembly; it is not evidence of mass production.
My partPrototype testing, wiring, assembly, soldering and power calculations