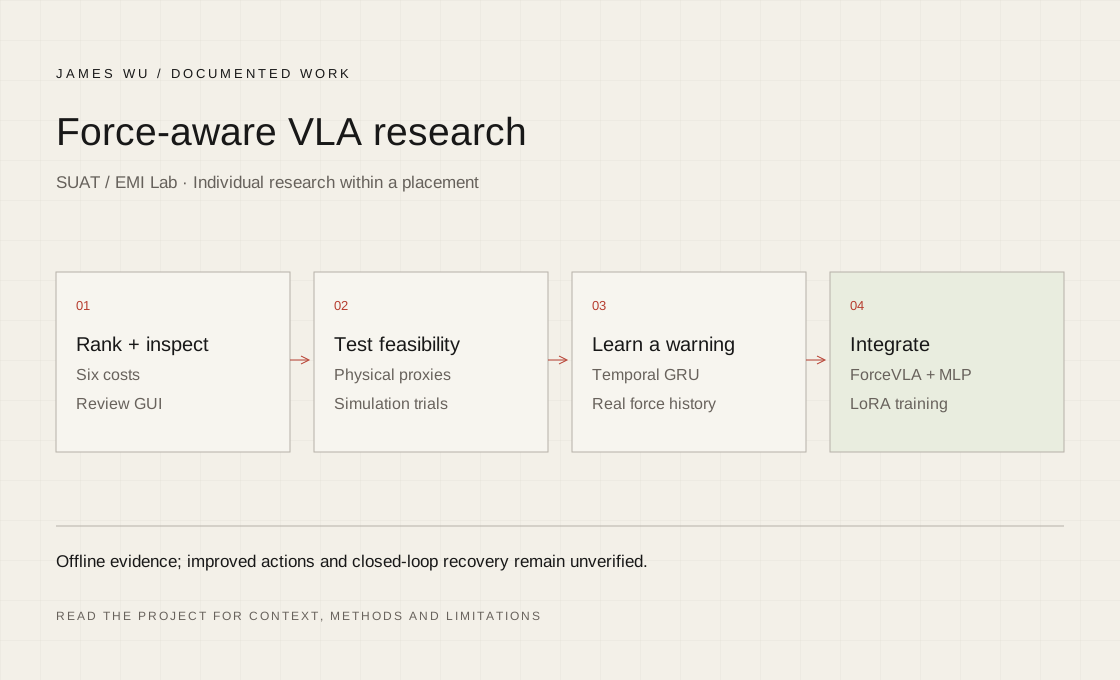
A standalone temporal model outperformed a current-force heuristic offline. The integrated ForceVLA risk head also learned the proxy risk signal; reliable action improvement and closed-loop performance remain unverified.
Independent projectIndependent research: trajectory ranking, simulation and risk-head training
Hands-on experience connecting physical robots, perception, control and services through task demonstrations, teleoperation, navigation experiments and hardware work.
My partTechnical Support Engineer Intern · robot applications and testing
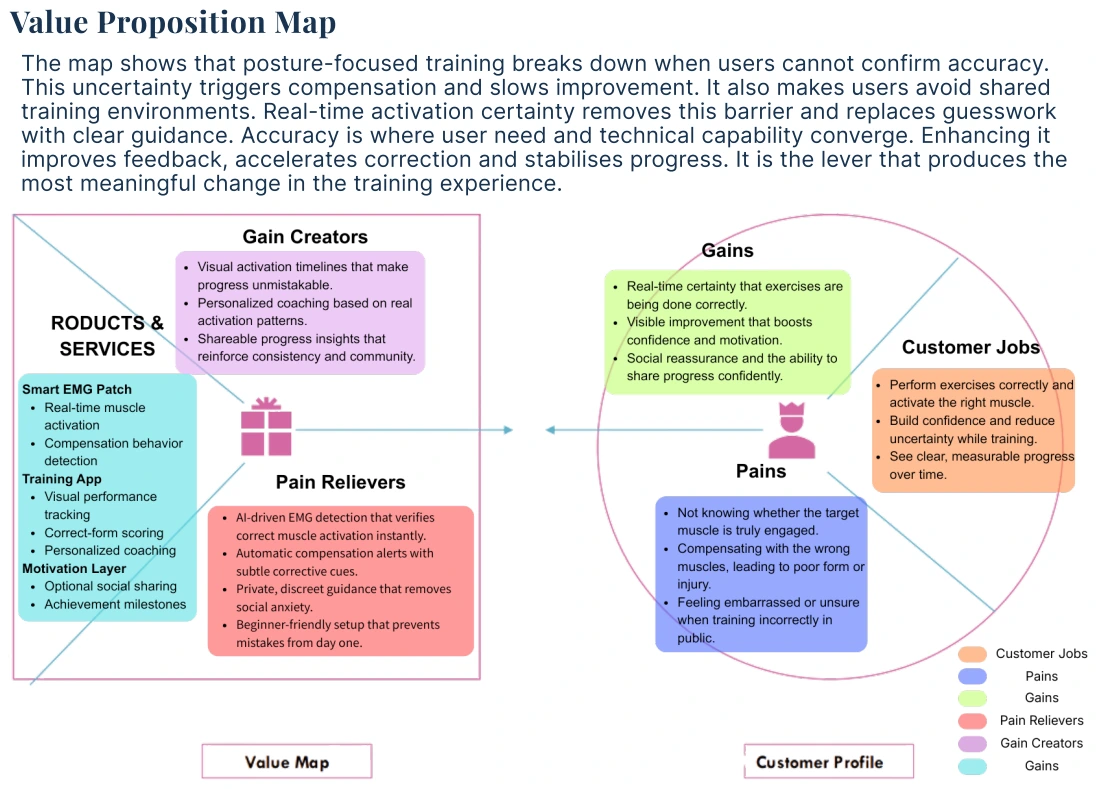
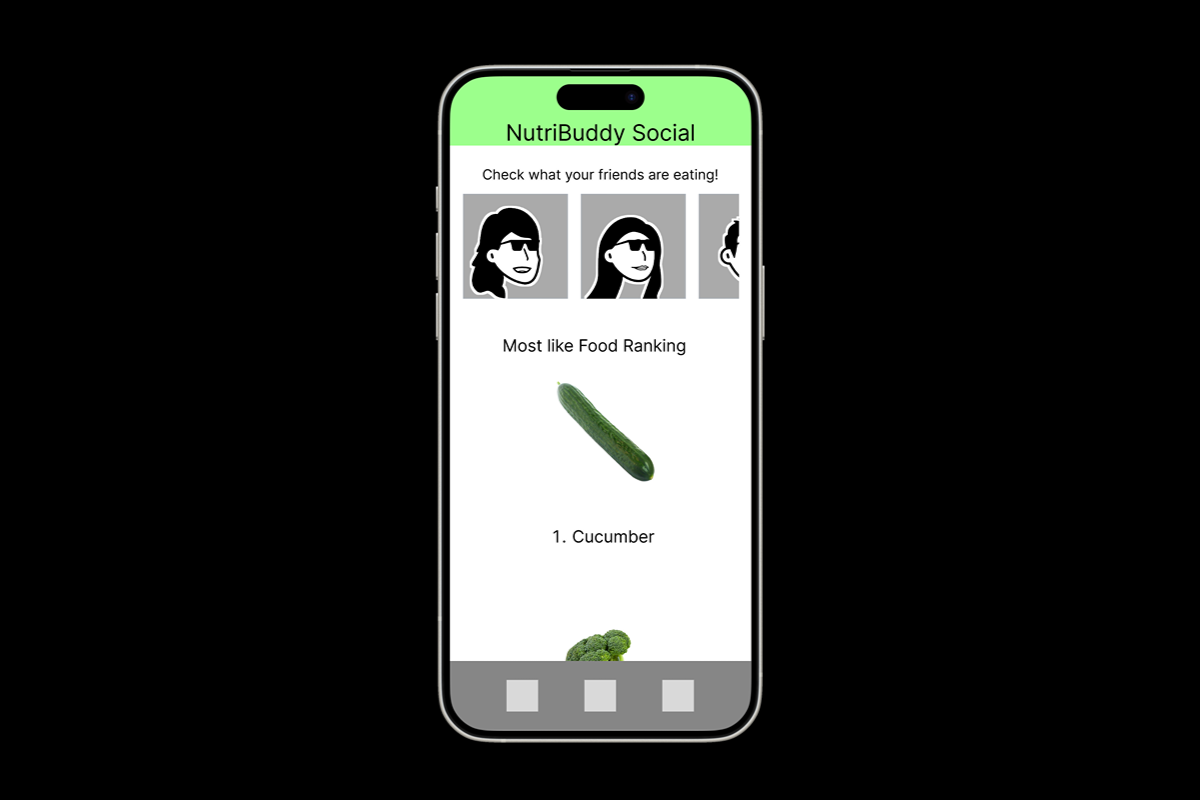
A concept and business case, including value proposition, acquisition channels and retention scenarios. This is not a launched service or a clinically validated training product.
Independent projectResearch, systems and commercial modelling
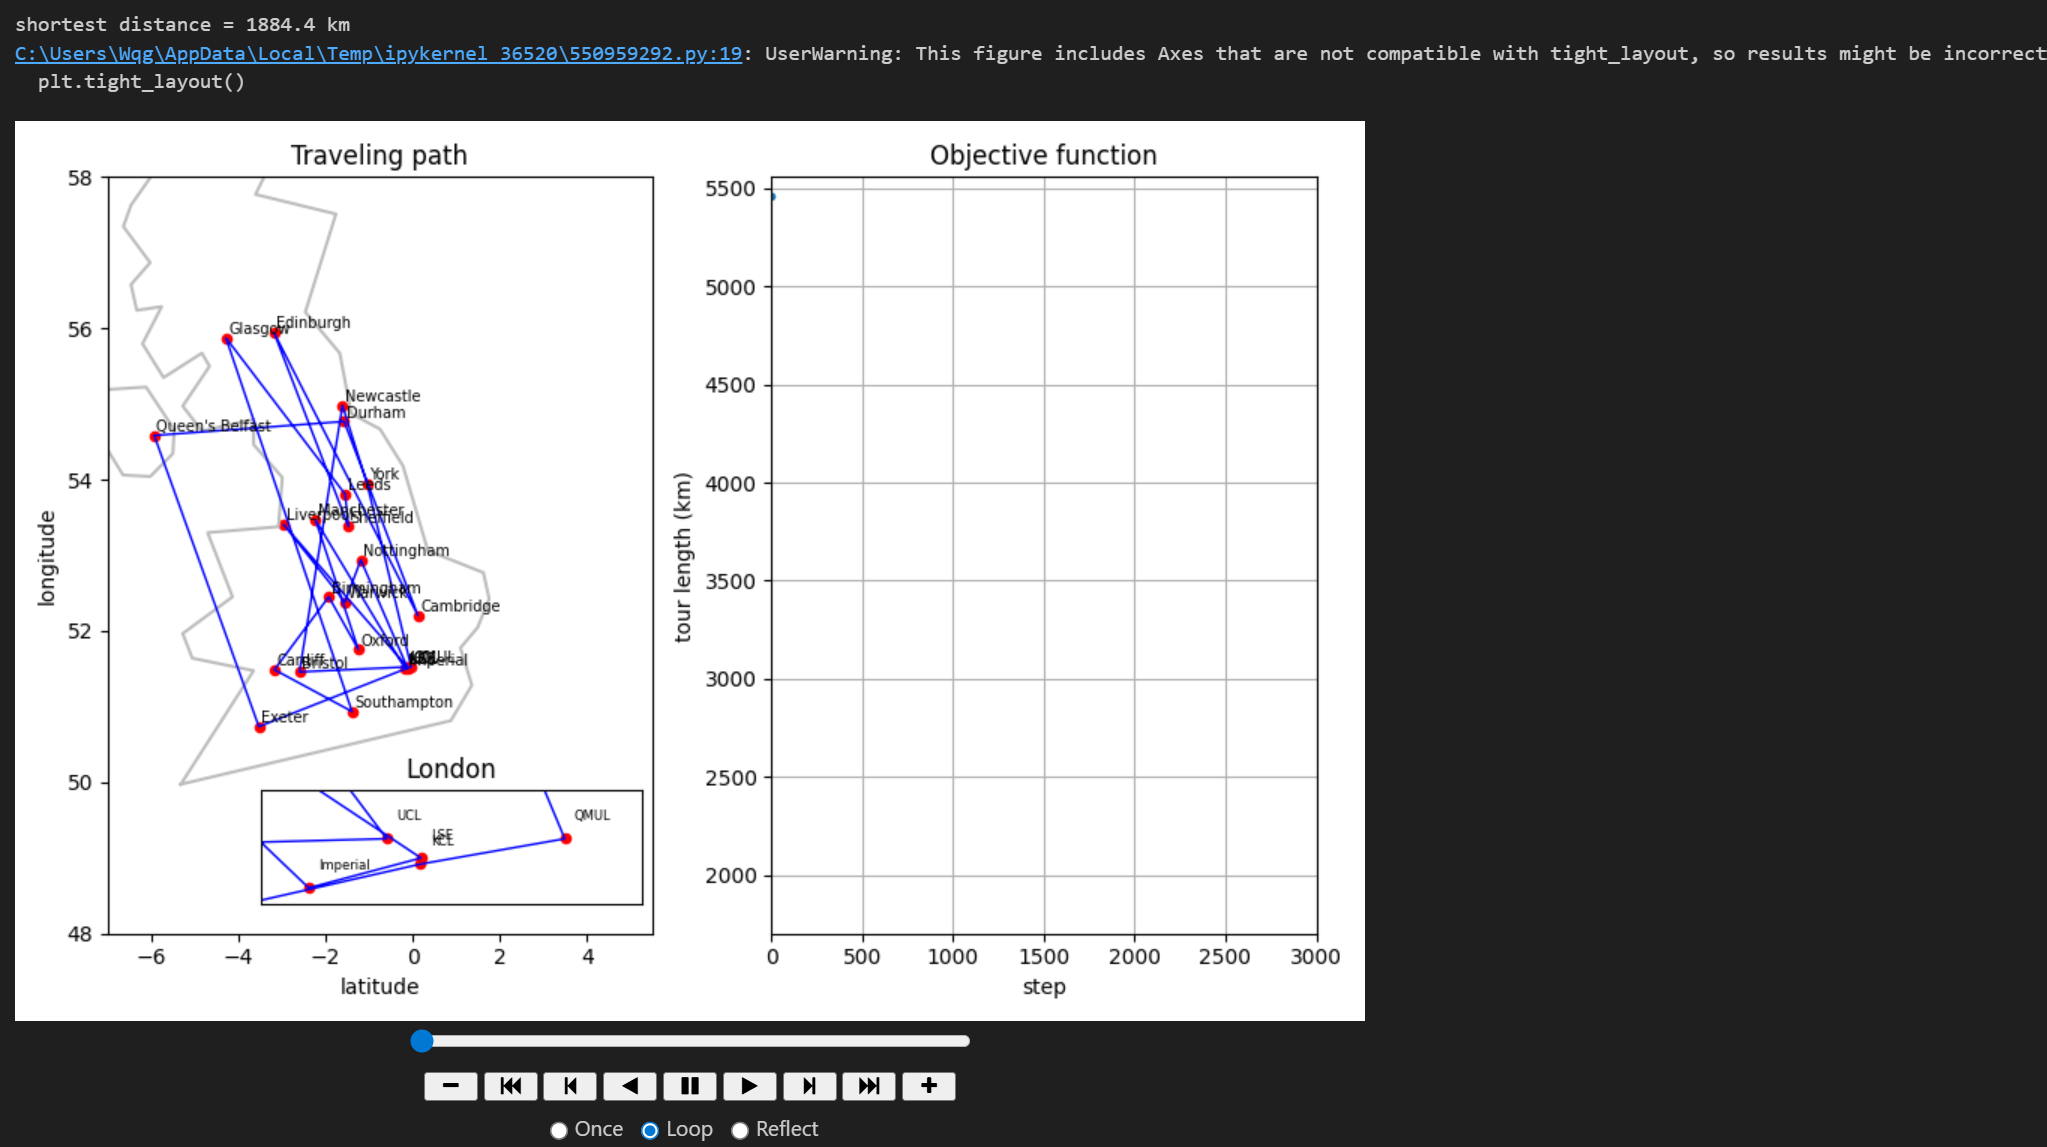
Implemented the requested algorithm functions within course scaffolding and inspected search trajectories across continuous, permutation and graph problems.
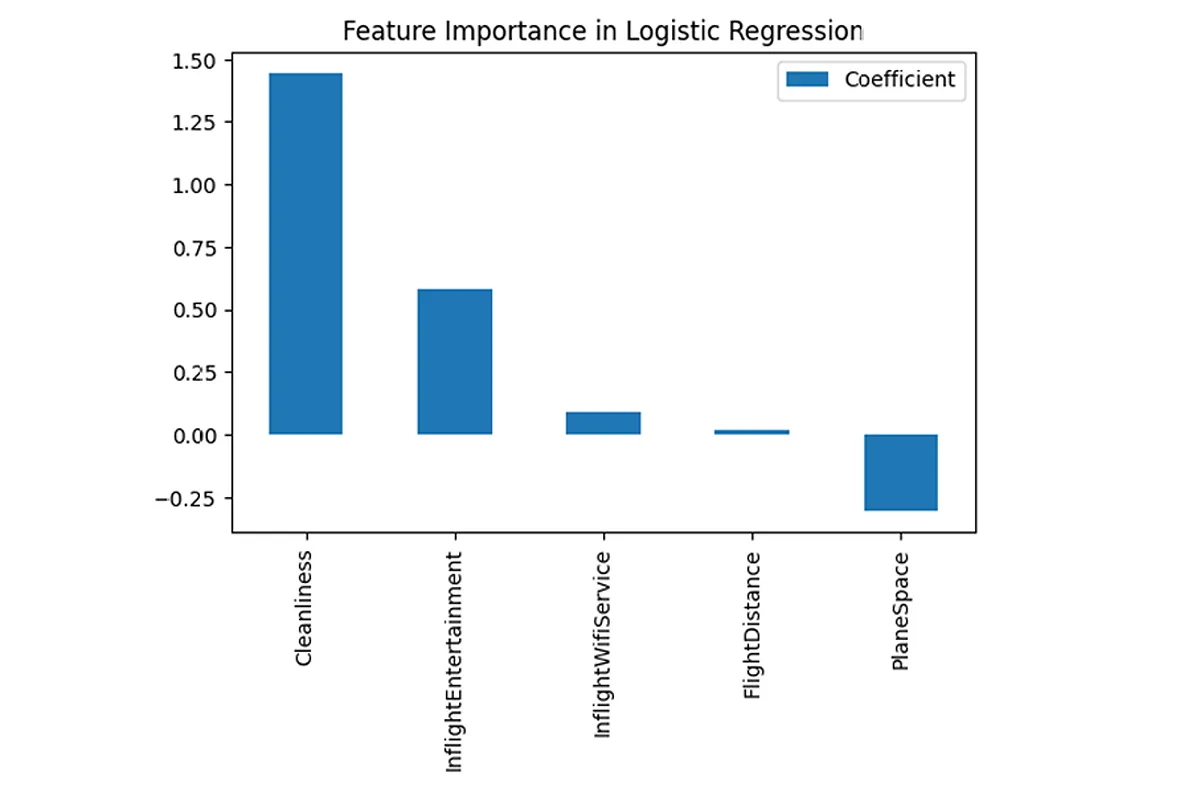
The selected model reached 0.85 test accuracy and 0.82 recall on the report’s split. The result concerns the seat-comfort target and does not establish causal effects of service changes.
Independent projectIndependent logistic-regression analysis within a course report
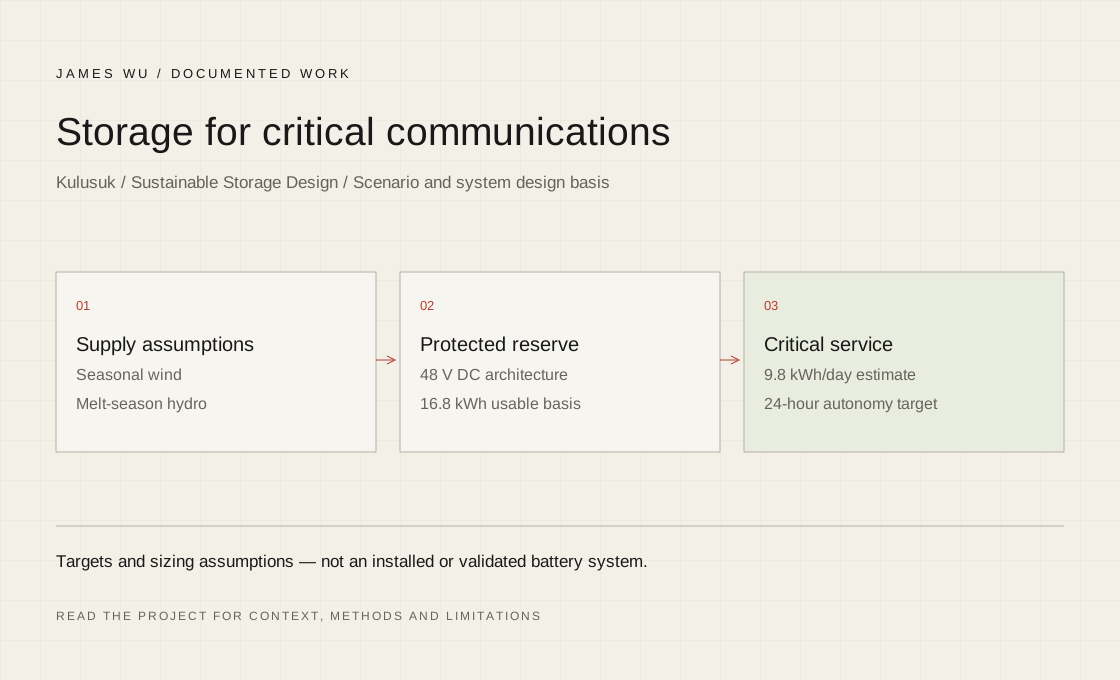
Defined a 48 V DC architecture, load priorities, 24-hour autonomy target, heating demand and usable-energy requirement for downstream battery, BMS and transient-support design.
My partCollaborative storage-system design; scenario and design-basis report author
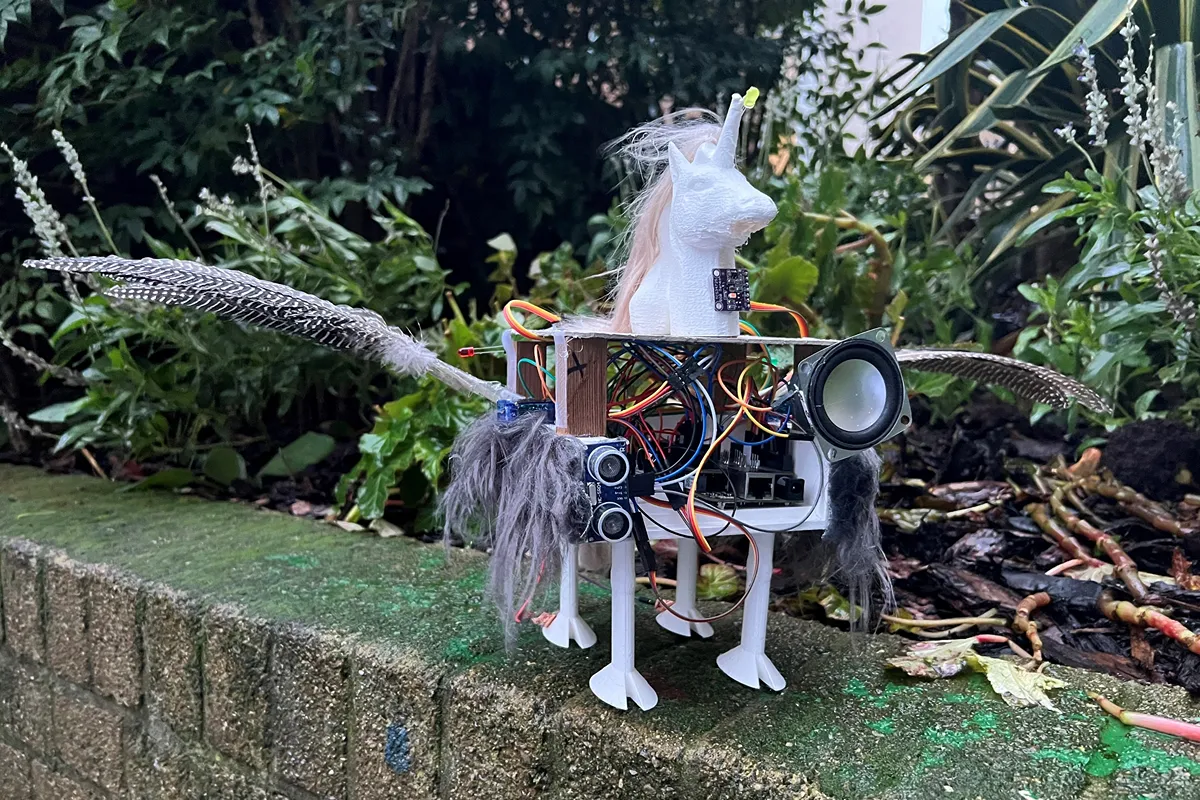
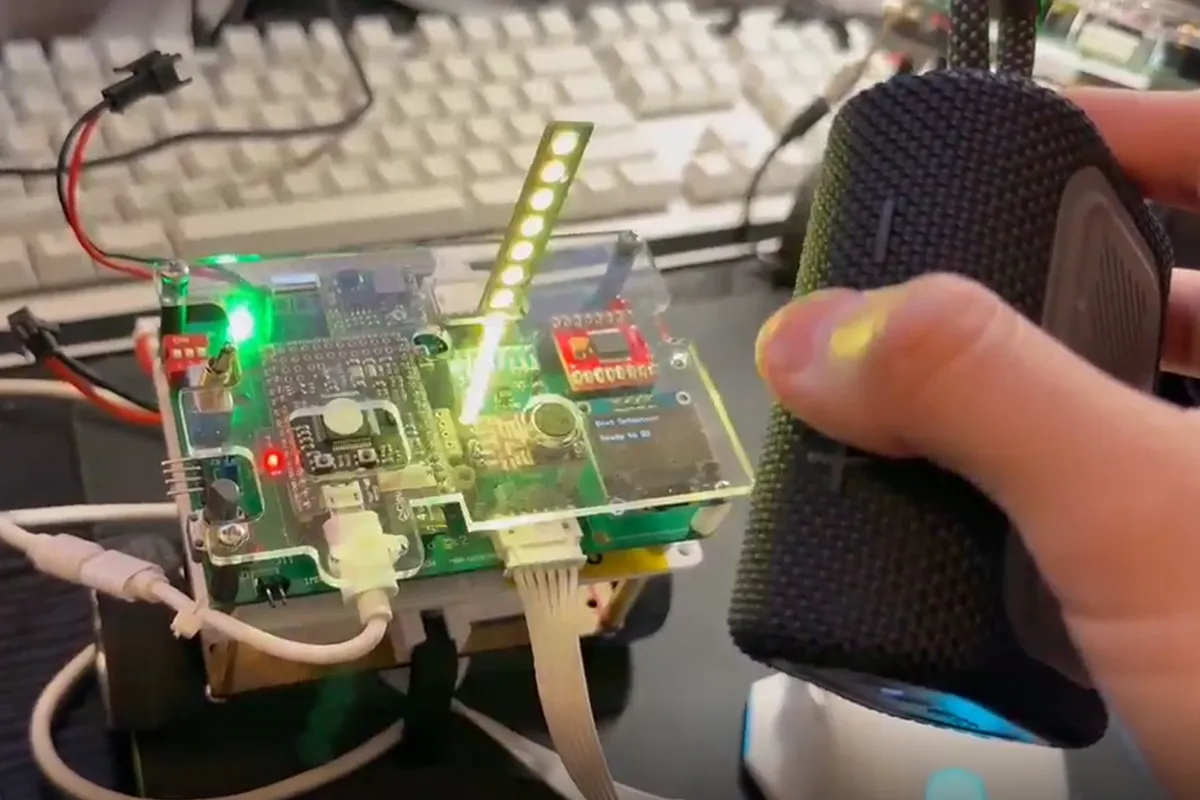
Built and tested a physical prototype, identifying fit, wiring, power and control issues. The production-oriented CAD proposes injection-moulded parts and modular assembly; it is not evidence of mass production.
My partPrototype testing, wiring, assembly, soldering and power calculations