Humanoid and wheeled platforms
Robot operation, policy-related demonstration collection and hardware assembly.
At Dobot Robotics, I worked with humanoid and wheeled robots on operation, policy-related data collection and hardware assembly. My placement also covered navigation experiments, vision-guided manipulation and speech interaction.
 Inspect full-size image ↗
Open a chapter to follow the work and the choices made along the way.
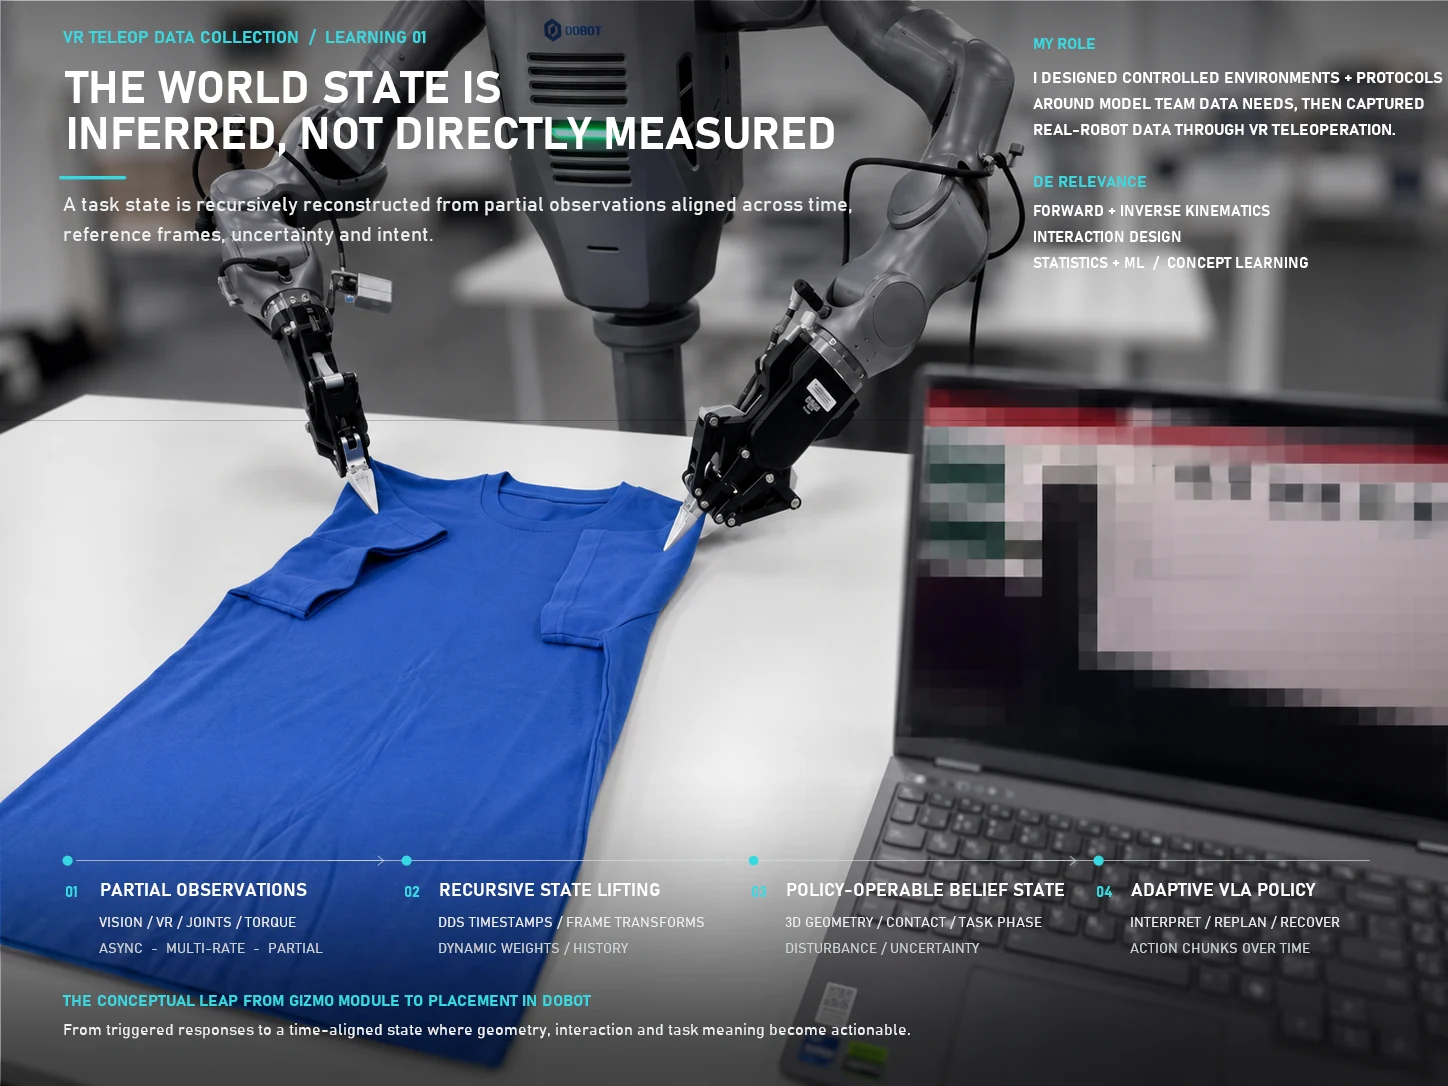
Teleoperated manipulation tasks were divided into clear phases and short action chunks. Environmental variation was added after the task sequence was stable.
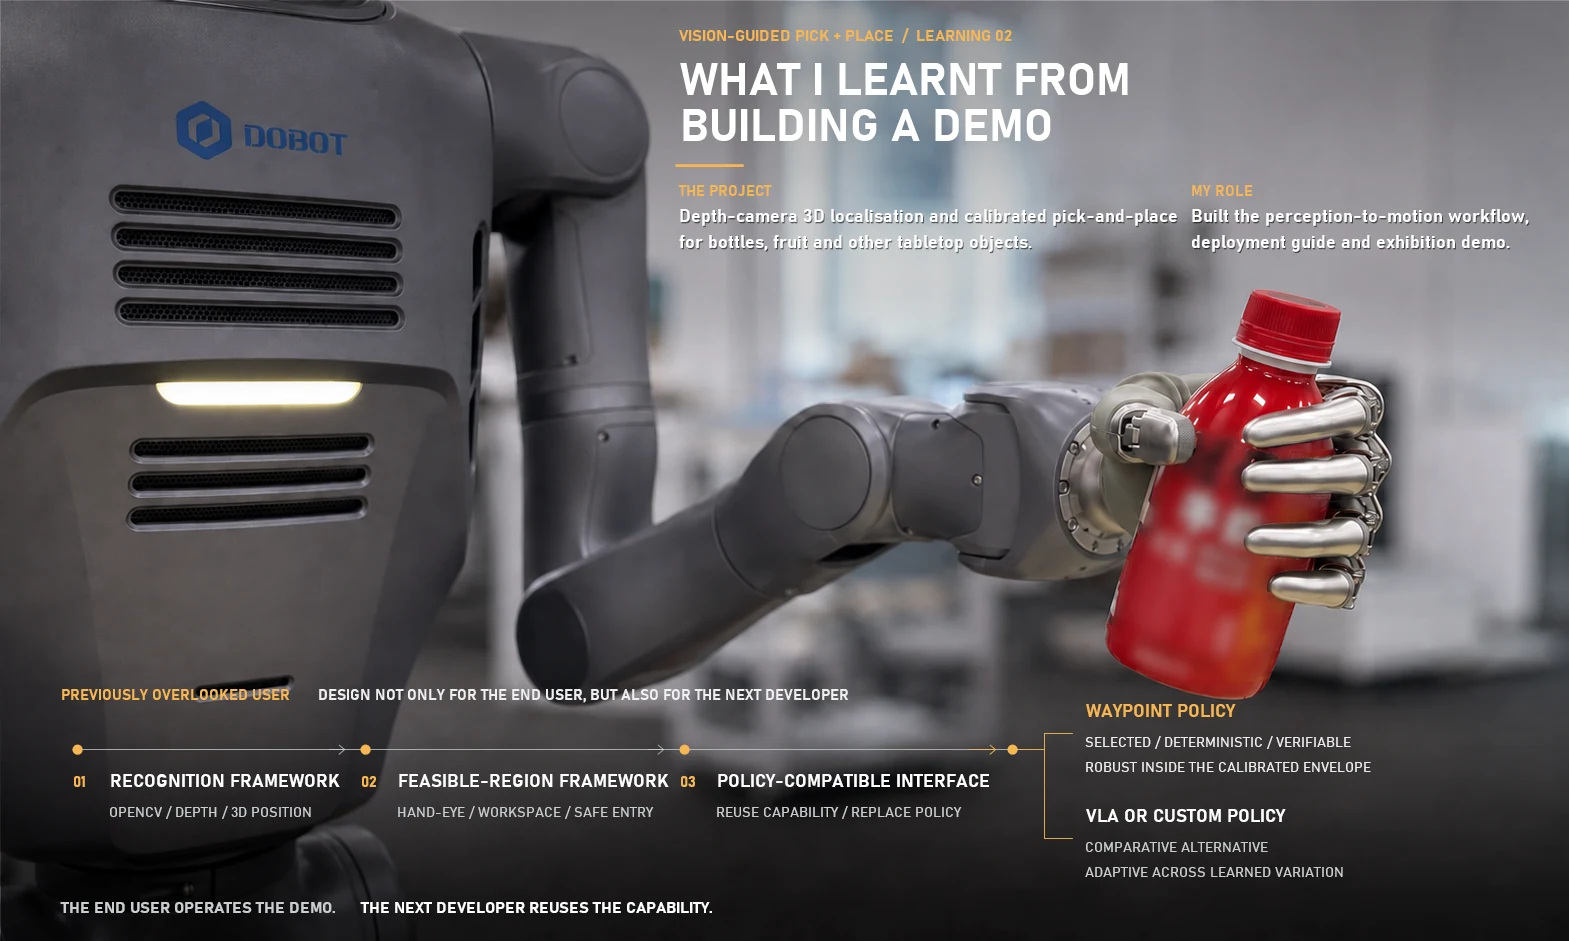
Inspect the supporting evidence ↓The documented workflow combines object detection and segmentation, depth and hand-eye calibration, then robot-frame targets and fixed grasp/transfer waypoints. Results apply to a fixed object in the calibrated workspace.
Inspect the supporting evidence ↓I explored planning with an incomplete map in Isaac Sim, using global guidance and local MPPI. The review’s replay reached the step limit; its value is the decision trace and failure analysis, not a successful navigation benchmark.
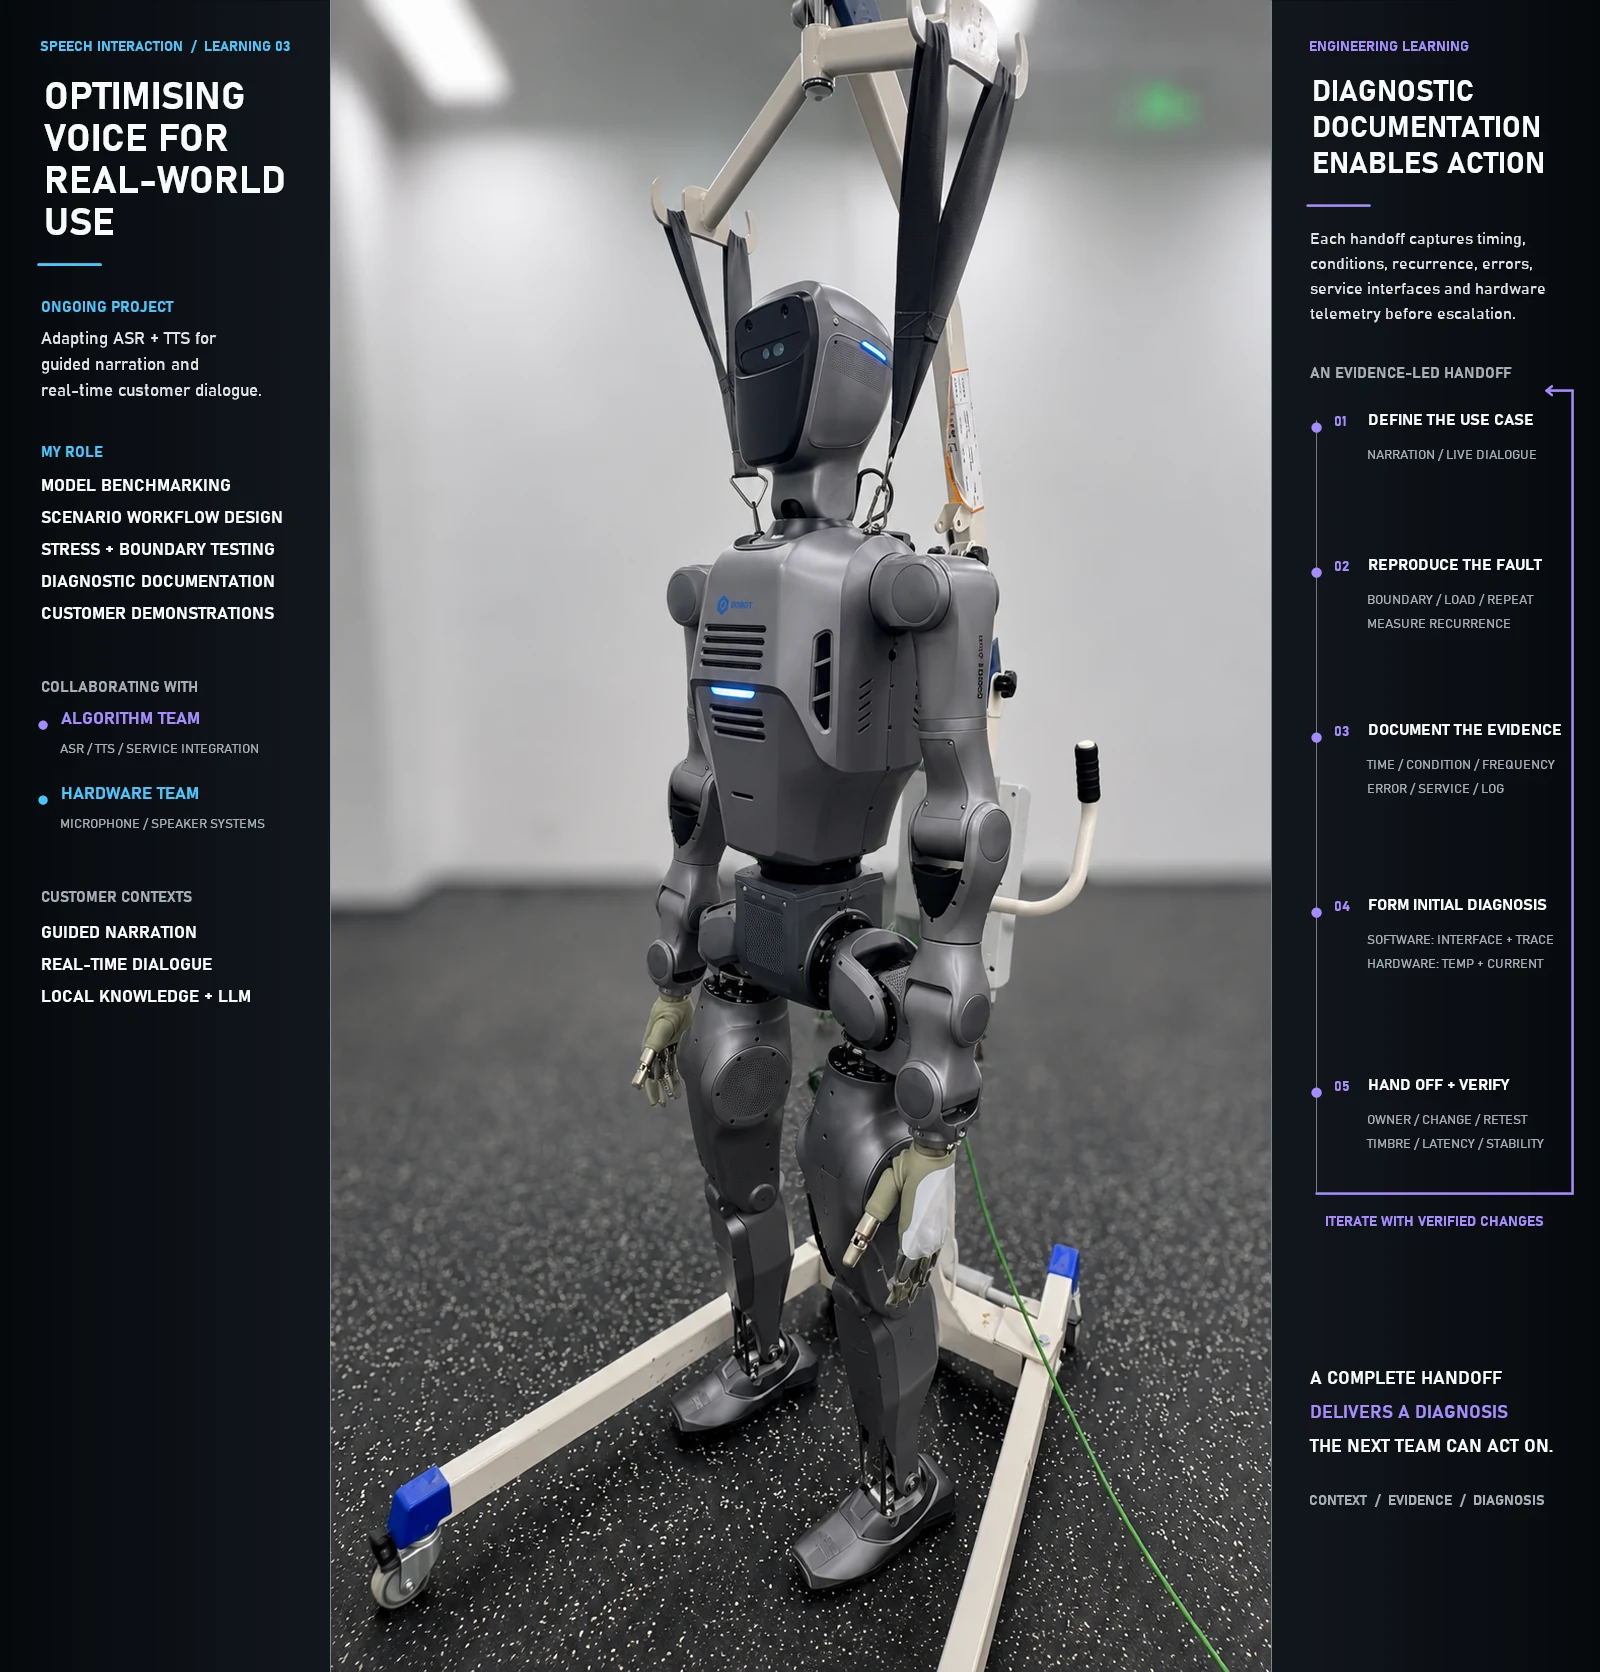
Inspect the supporting evidence ↓Guide-robot work covered speech recognition, routing between a knowledge base and a general model, speech output and robot actions. Diagnostic work also involved reproducing faults and documenting operating conditions.
Inspect the supporting evidence ↓Internship contributions across several workstreams. The manipulation result is limited to the calibrated demonstration; exploratory navigation is not a benchmark success.
Robot operation, policy-related demonstration collection and hardware assembly.
Repeated transfer of a fixed object within a calibrated workspace. No general-purpose grasp success rate is claimed.
Application development and testing across perception, control, services and hardware.
High-level workstreams and evaluation boundaries.
Humanoid and wheeled robots, policy-related work and hardware assembly.
Related by practice, not just by category.
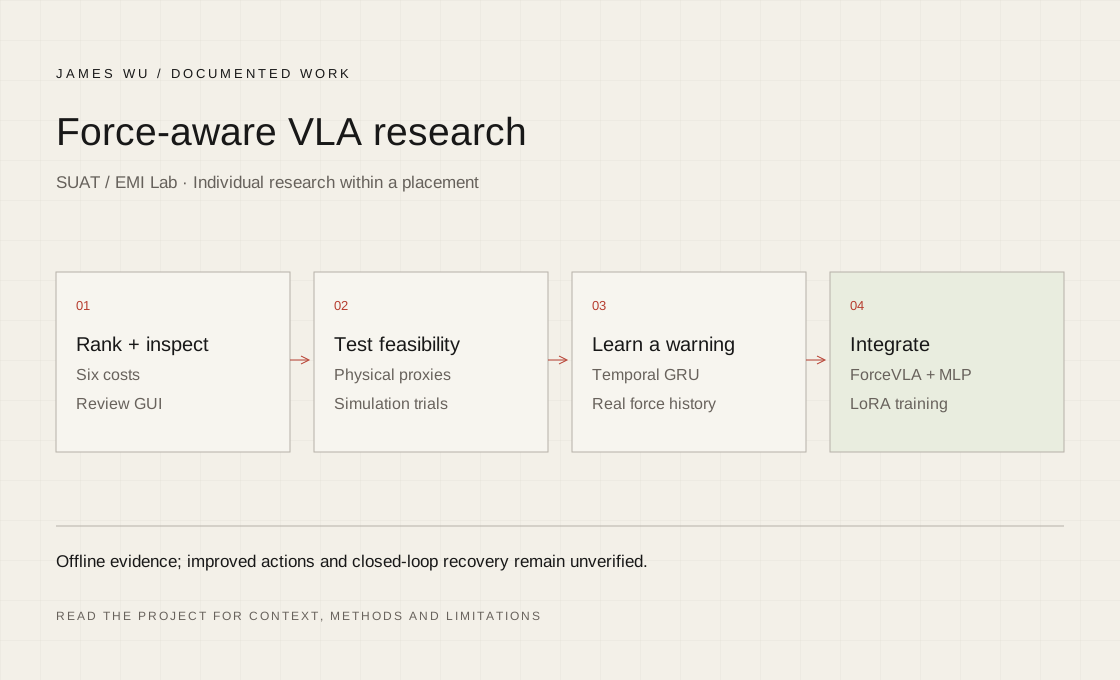
A standalone temporal model outperformed a current-force heuristic offline. The integrated ForceVLA risk head also learned the proxy risk signal; reliable action improvement and closed-loop performance remain unverified.
Independent projectIndependent research: trajectory ranking, simulation and risk-head training
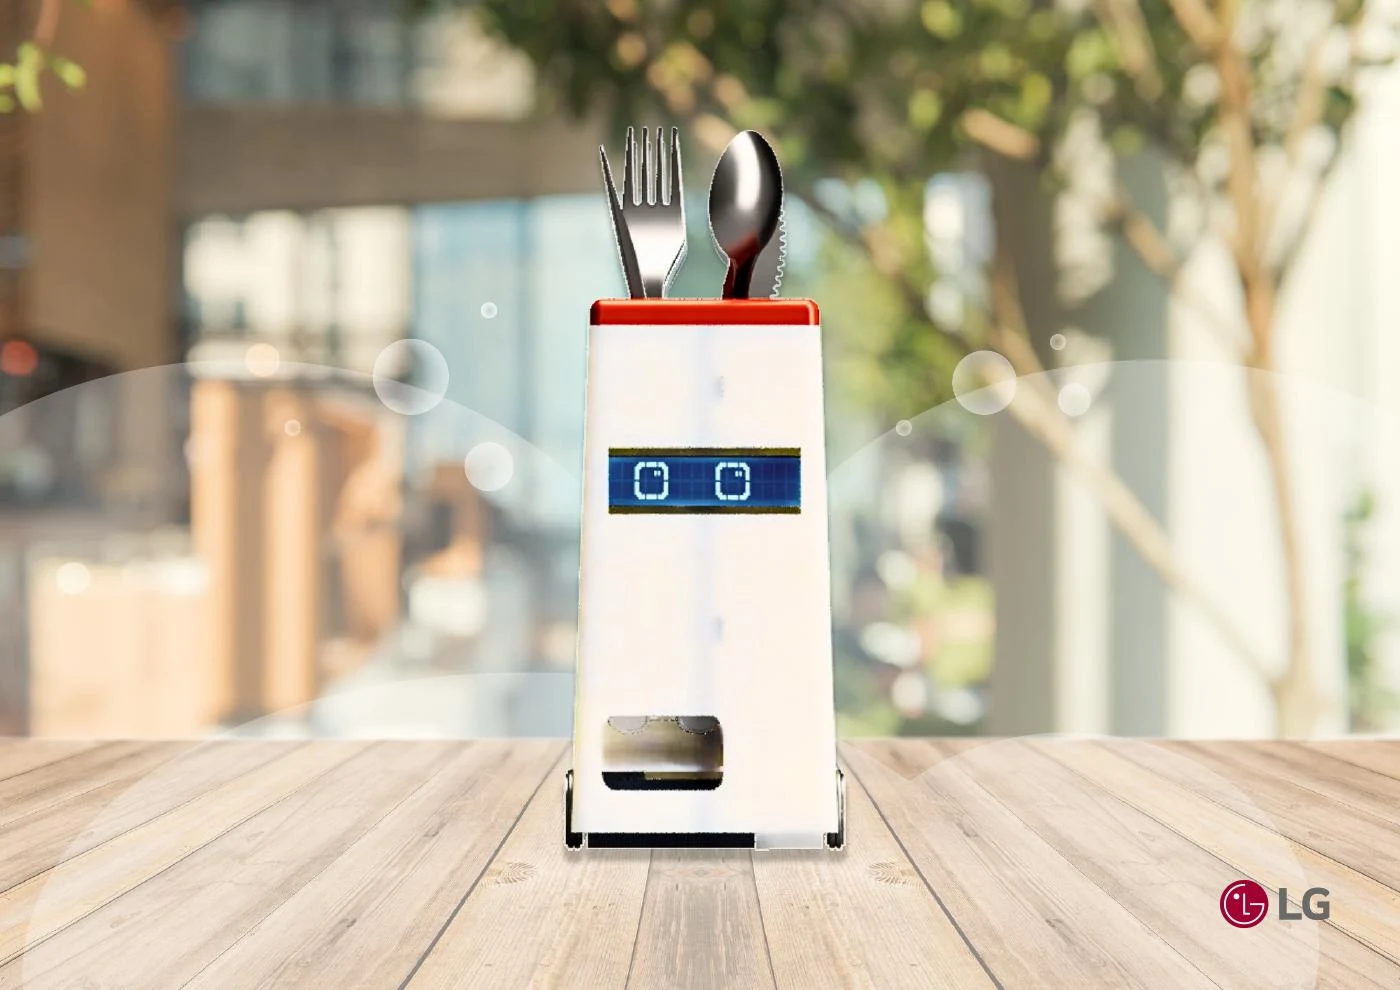
Built and tested a physical prototype, identifying fit, wiring, power and control issues. The production-oriented CAD proposes injection-moulded parts and modular assembly; it is not evidence of mass production.
My partPrototype testing, wiring, assembly, soldering and power calculations
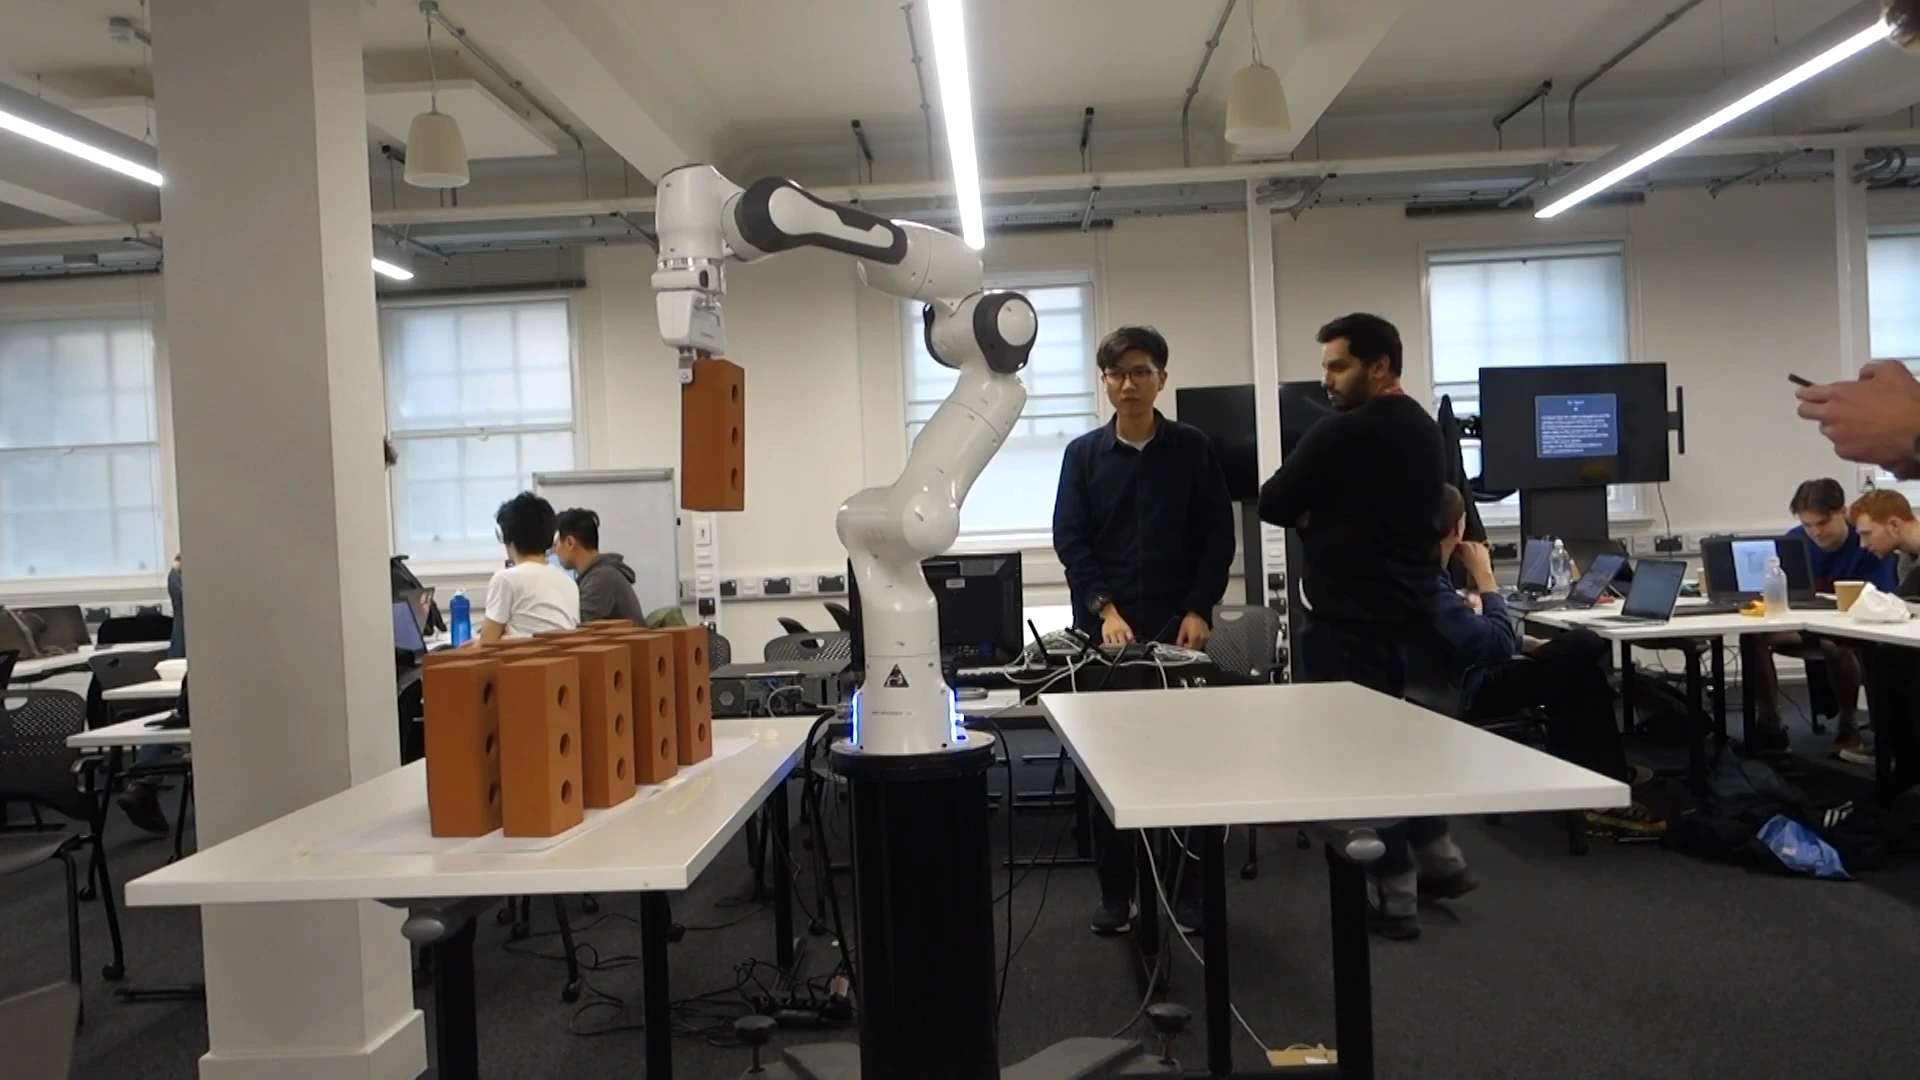
Completed basic physical-arm manipulation and brick-stacking tasks using waypoint-defined motions.
Independent projectRobot operation and waypoint setup